Track Ego
Track Ego
Tracking and Motion Prediction for Autonomous Vehicles — Graduation Thesis, Cairo University
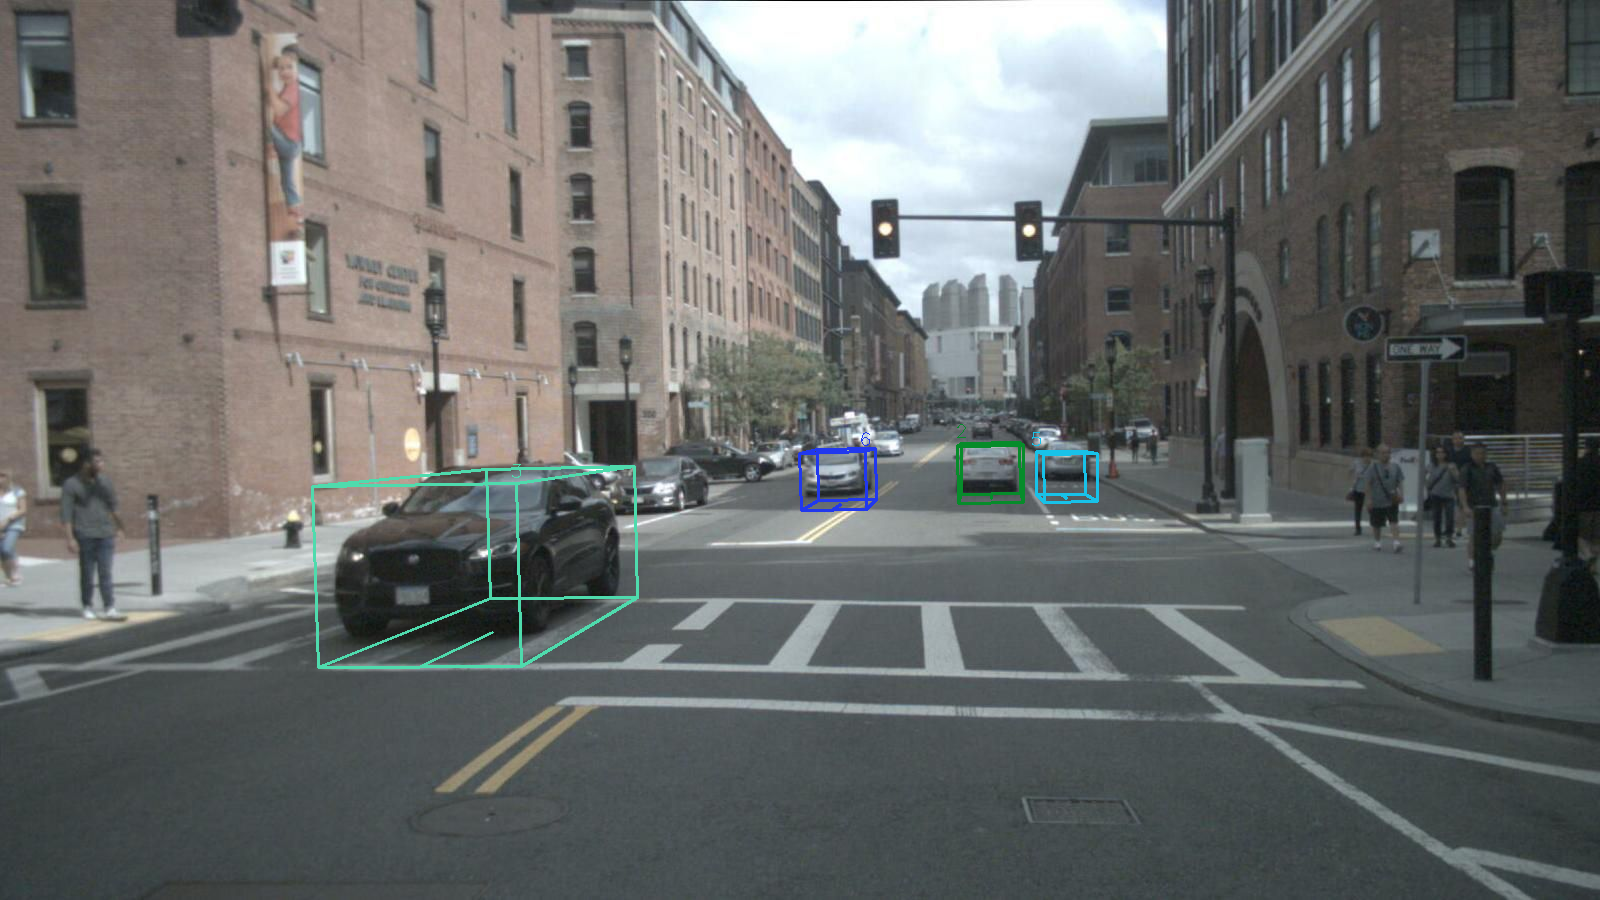
Overview
Reaching and building a complete perception system capable of detecting, tracking, and predicting the motion of other vehicles on the road, to be used in autonomous cars.
- Conducted an extensive literature review of existing motion prediction techniques.
- Provided accurate predictions for the future trajectories of surrounding vehicles on the nuScenes dataset while maintaining 15-FPS speed.
- Utilized the transformer architecture to build encoders capturing both the spatial interactions between agents and the temporal interactions between their historical trajectories.
Technologies
Python · PyTorch · Linux · Git